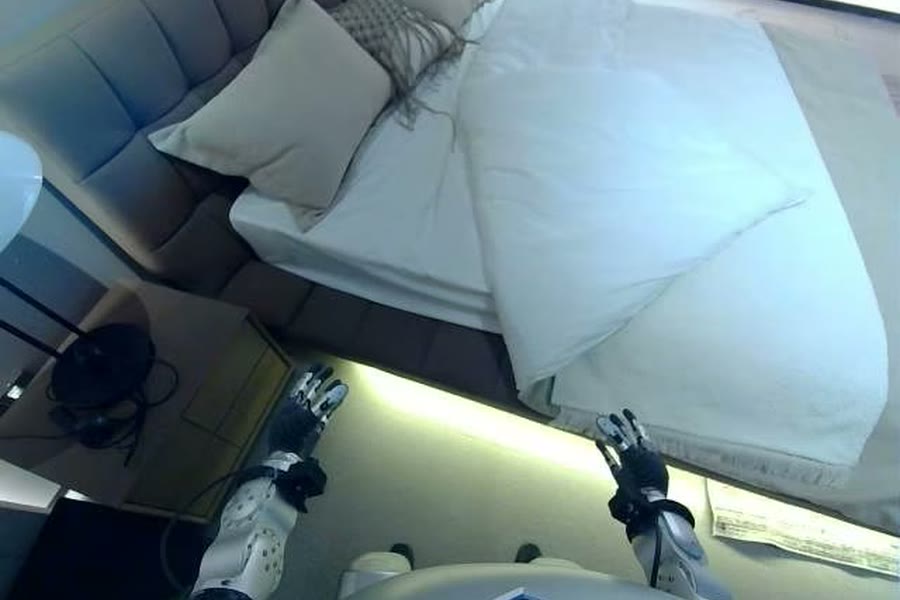
Frame from the UnifoLM WBT Dataset (G1_WBT_Brainco_Make_The_Bed), Unitree Robotics, Apache 2.0.
Apache 2.0
The publisher's licence permits commercial use and redistribution, with attribution. Hub card tag apache-2.0 on all 55 repos, applied by Unitree's own organisation; the card bodies carry no licence sentence of their own.
hf download unitreerobotics/G1_WBT_Brainco_Make_The_Bed --repo-type dataset --local-dir ./G1_WBT_Brainco_Make_The_BedOne public repo per task and hand type, 55 in all, listed in the collection; the command pulls one. AV1 video. Several tasks exist in a v0 and a later repo. Four repos outside the collection (three MainCamOnly copies and one Inspire dishwasher set) are not counted here.
Specification, as published
- Hours (derived)
- 132 h
- Episodes (stated)
- 12,641 episodes
- Task
- Tidying & put-away, Laundry & folding, Cleaning, Dishwashing, Pick & place, Sorting & packing +2 more
- Environment
- Indoor – home
- Modality
- RGB, Stereo, Infrared, Proprioception, Actions
- Capture
- Egocentric
- In frame
- Robot hands
- Captured in
- Asia
- Embodiment
- Unitree G1 humanoid with Brainco dexterous hands, Unitree G1 with Inspire dexterous hands, Unitree G1 with Dex1 parallel grippers
- Frame rate
- 30 fps
- Resolution
- 640x480
- Formats
- LeRobot v3.0, Parquet, MP4
- Size
- about 827 GB on the Hub across 55 repos
- Hosted on
- Hugging Face
Figures are the publisher's own. Kinetic Blocks has not measured this dataset. Derived from the meta/info.json of all 55 repos: 14,267,939 frames at 30 fps. Frames are timesteps and are not summed across camera views.
About this dataset
Mobile manipulation on a Unitree G1 humanoid where the action space spans both arms, both legs, the waist, base motion and end-effector pose: the robot walks while it works. End effectors are Brainco dexterous hands, Inspire dexterous hands or Dex1 grippers. Tasks centre on home and care settings: making and tidying beds, loading the washing machine and dishwasher, putting drinks in the fridge, hanging clothes, cleaning the living room, organising a supermarket shelf, adjusting a sickbed and pushing a wheelchair. Each episode has a head stereo pair and wrist cameras at 640x480 and 30 fps (some repos add raw and rectified stereo and wrist infrared), with full-body joint states, base pose and base rotation, and the matching actions. Unitree positions it for household manipulation learning and world-model training.
Publisher's own task names: make the bed, tidy the bed, put clothes into washing machine, put clothes into basket, hang up clothes, collect plates into dishwasher, put plate into dishwasher, put drinks into fridge, put vegetables into basket, pick up medicine, clean the living room, tidy living room slippers.
What Kinetic Blocks did, and did not do
Indexed and linked from the publisher. Not hosted, verified or graded by Kinetic Blocks. The publisher's terms govern. The licence shown is the one stated on the publisher's page, linked above. Nothing on this page is a claim by Kinetic Blocks.
Want the verified ones too?
Request access to the marketplace, where verified listings are checked against their files and graded A+ to F, and your money waits until the data holds up.