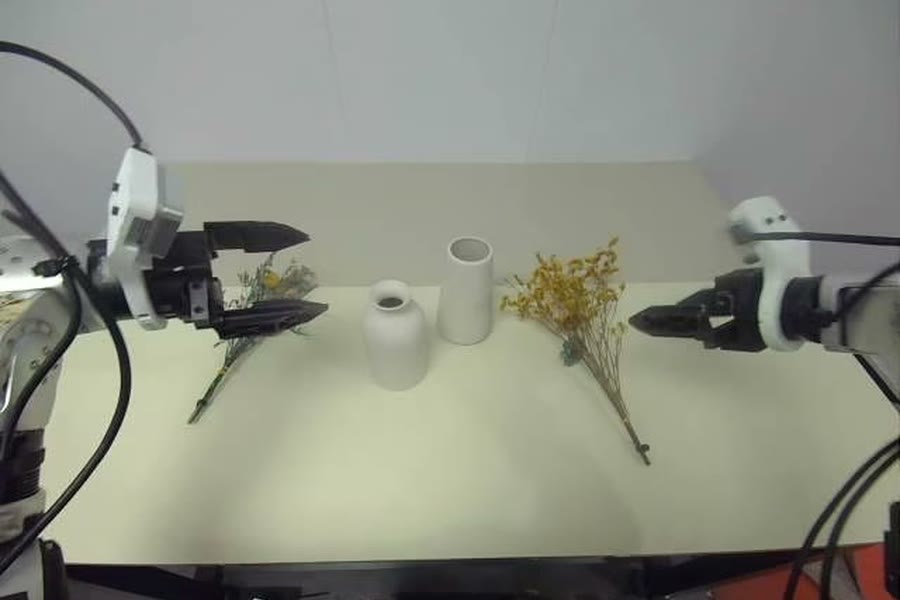
Frame from the UnifoLM G1 Table-top Manipulation Dataset (G1_Dex1_Arrange_Flowers), Unitree Robotics, Apache 2.0.
Apache 2.0
The publisher's licence permits commercial use and redistribution, with attribution. Hub card tag apache-2.0 on all 93 repos, applied by Unitree's own organisation; older cards repeat it in the LeRobot template line, none adds a licence sentence of its own.
hf download unitreerobotics/G1_Dex3_BlockStacking_Dataset --repo-type dataset --local-dir ./G1_Dex3_BlockStacking_DatasetThree sub-collections (Dex1 about 1.59 TB, Dex3 about 147 GB, Brainco about 118 GB), one public repo per task; the command pulls one Dex3 repo. Newer repos are AV1-encoded. A few tasks appear twice under slightly different names, for example G1_Dex1_Fold_Towel (v2.1) and G1_Dex1_FoldTowel.
Specification, as published
- Hours (derived)
- 227 h
- Episodes (stated)
- 34,642 episodes
- Task
- Pick & place, Tidying & put-away, Sorting & packing, Cleaning, Cooking & food prep, Laundry & folding +2 more
- Environment
- Indoor – lab
- Modality
- RGB, Stereo, Infrared, Proprioception, Actions
- Capture
- Egocentric
- In frame
- Robot hands
- Captured in
- Asia
- Embodiment
- Unitree G1 humanoid with Dex1 parallel grippers, Unitree G1 with Dex3 three-fingered hands, Unitree G1 with Brainco dexterous hands
- Frame rate
- 30 fps
- Resolution
- 640x480
- Formats
- LeRobot v3.0, LeRobot v2.1, Parquet, MP4
- Size
- about 1.85 TB on the Hub across 93 repos
- Hosted on
- Hugging Face
Figures are the publisher's own. Kinetic Blocks has not measured this dataset. Derived from the meta/info.json of all 93 repos: 24,475,743 frames at 30 fps (Dex1 20,231,912; Dex3 2,587,515; Brainco 1,656,316). Frames are timesteps and are not summed across camera views.
About this dataset
Unitree's foundation set for training general manipulation models, published as three sub-collections by end effector: Dex1 parallel grippers (72 repos, about 187 hours), Dex3 three-fingered hands (13 repos, about 24 hours) and Brainco dexterous hands (8 repos, about 15 hours). Scenes cover household storage, kitchen, assembly, cleaning, clothing and production-line sorting, with grasp and place, stacking, pouring, wiping, pressing and switching skills. Episodes carry head stereo and wrist cameras at 640x480 and 30 fps (some newer Dex1 repos add wrist infrared), with arm and hand joint states and actions. The earliest repos date from February 2025 and Unitree is still adding to the Dex1 set.
Publisher's own task names: household storage, kitchen, assembly, cleaning, clothing, production-line sorting, grasp and place, stacking, pouring, wiping, pressing, switching.
What Kinetic Blocks did, and did not do
Indexed and linked from the publisher. Not hosted, verified or graded by Kinetic Blocks. The publisher's terms govern. The licence shown is the one stated on the publisher's page, linked above. Nothing on this page is a claim by Kinetic Blocks.
Want the verified ones too?
Request access to the marketplace, where verified listings are checked against their files and graded A+ to F, and your money waits until the data holds up.