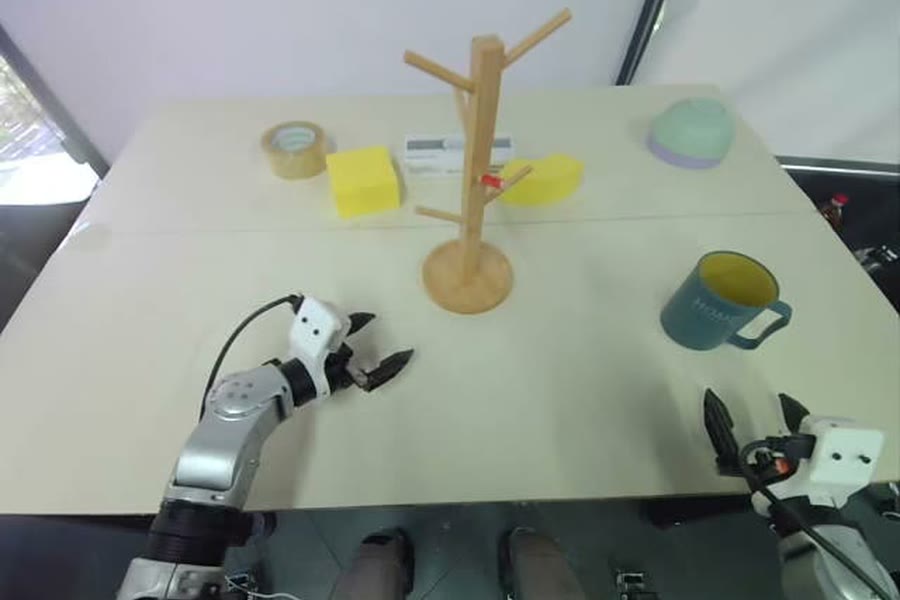
Frame from the UniBot-V1 Challenge Dataset (G1_Dex1_HangCup), Unitree Robotics, Apache 2.0.
Apache 2.0
The publisher's licence permits commercial use and redistribution, with attribution. Hub card tag apache-2.0 on all 32 repos, applied by Unitree's own organisation; the card bodies carry no licence sentence of their own.
hf download unitreerobotics/G1_Dex1_HangCup --repo-type dataset --local-dir ./G1_Dex1_HangCupOne public repo per task, 32 in all, listed in the collection; the command pulls one (HangCup). Repos average about 25 GB. LeRobot v3.0 with AV1 video, which needs a decoder with AV1 support.
Specification, as published
- Hours (derived)
- 169 h
- Episodes (stated)
- 33,276 episodes
- Scale
- over 160 hours, 33,000 task trajectories, 32 real-world tabletop manipulation tasks
- Task
- Pick & place, Tidying & put-away, Sorting & packing, Laundry & folding, Assembly, Electrical work +1 more
- Environment
- Indoor – lab
- Modality
- RGB, Stereo, Proprioception, Actions
- Capture
- Egocentric
- In frame
- Robot hands
- Captured in
- Asia
- Embodiment
- Unitree G1 humanoid with Dex1 parallel grippers
- Frame rate
- 30 fps
- Resolution
- 640x480
- Formats
- LeRobot v3.0, Parquet, MP4
- Size
- about 811 GB on the Hub across 32 repos
- Hosted on
- Hugging Face
Figures are the publisher's own. Kinetic Blocks has not measured this dataset. Derived from the meta/info.json of all 32 repos: 18,282,246 frames at 30 fps. Frames are timesteps and are not summed across the four camera views. Unitree's own page says over 160 hours.
About this dataset
The dataset behind Unitree's UniBot World Challenge: a G1 humanoid with Dex1 parallel grippers teleoperated through 32 tabletop tasks, one Hugging Face repo per task. Tasks run from grasp and place to two-handed coordination: hanging cups, arranging plates and test tubes, zipping up, unlocking, plugging in chargers and Ethernet, conveyor sorting, folding towels, organising bookshelves and stationery, and transferring water with a syringe. Each episode carries a rectified head stereo pair and two wrist cameras at 640x480 and 30 fps, AV1-encoded, plus arm, gripper, leg and waist joint states, end-effector poses and the matching action streams.
Publisher's own task names: hang cup, arrange plates, arrange test tubes, zip up, colour arrangement, unlock, disconnect Ethernet, plug in Ethernet, plug charger, conveyor sorting, fruit collection, fruit sorting.
What Kinetic Blocks did, and did not do
Indexed and linked from the publisher. Not hosted, verified or graded by Kinetic Blocks. The publisher's terms govern. The licence shown is the one stated on the publisher's page, linked above. Nothing on this page is a claim by Kinetic Blocks.
Want the verified ones too?
Request access to the marketplace, where verified listings are checked against their files and graded A+ to F, and your money waits until the data holds up.