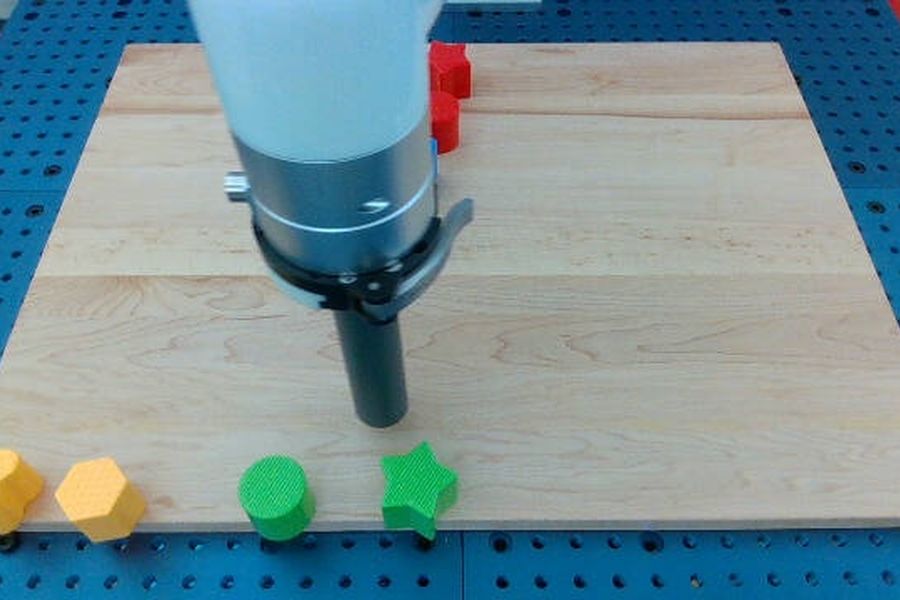
Frame from the Language-Table dataset, Google Robotics, Apache 2.0 (CC BY 4.0 via Open X-Embodiment).
Apache 2.0 (CC BY 4.0 via Open X-Embodiment)
The publisher's licence permits commercial use and redistribution, with attribution. Repository is Apache 2.0; the same data ships under CC BY 4.0 inside Open X-Embodiment. Both permit commercial use.
gsutil -m cp -r gs://gresearch/robotics/language_table/0.0.1 .Nine separate TFDS directories: language_table (real, 442,226 episodes), language_table_sim (181,020), blocktoblock_sim (8,000), blocktoblock_4block_sim (8,298) and five oracle sim sets of 200,000 each. Bucket is public. Total size not published; the real split is large. Also mirrored inside Open X-Embodiment as language_table.
Specification, as published
- Hours (stated)
- 2,701 h
- Episodes (stated)
- 442,226 episodes
- Scale
- nearly 600,000 language-labeled trajectories
- Task
- Pick & place, Sorting & packing, Other
- Environment
- Indoor – lab
- Modality
- RGB, Actions, Language, Proprioception
- Capture
- CCTV Scene
- In frame
- Robot hands
- Captured in
- North America
- Embodiment
- UFACTORY xArm6 with cylindrical pusher end-effector (real and simulated)
- Frame rate
- 5 fps
- Resolution
- 640x360
- Formats
- RLDS/TFRecord
- Hosted on
- Google Cloud Storage
Figures are the publisher's own. Kinetic Blocks has not measured this dataset.
About this dataset
Language-Table is Google's dataset of language-conditioned tabletop block rearrangement with an xArm6 constrained to 2D pushing. The real-robot split holds 442,226 hindsight-relabelled trajectories drawn from about 2,700 hours of raw teleoperation, and eight simulated splits add human and scripted oracle data. Observations are RGB frames from a fixed RealSense camera plus effector translation actions and natural-language instructions, stored as TFDS/RLDS shards in the gresearch GCS bucket.
Publisher's own task names: block to block, block to block relative, block to absolute location, block to relative location, separate blocks, open-vocabulary language instructions.
What Kinetic Blocks did, and did not do
Indexed and linked from the publisher. Not hosted, verified or graded by Kinetic Blocks. The publisher's terms govern. The licence shown is the one stated on the publisher's page, linked above. Nothing on this page is a claim by Kinetic Blocks.
Want the verified ones too?
Request access to the marketplace, where every paid listing is verified against its files and graded before it goes on sale.