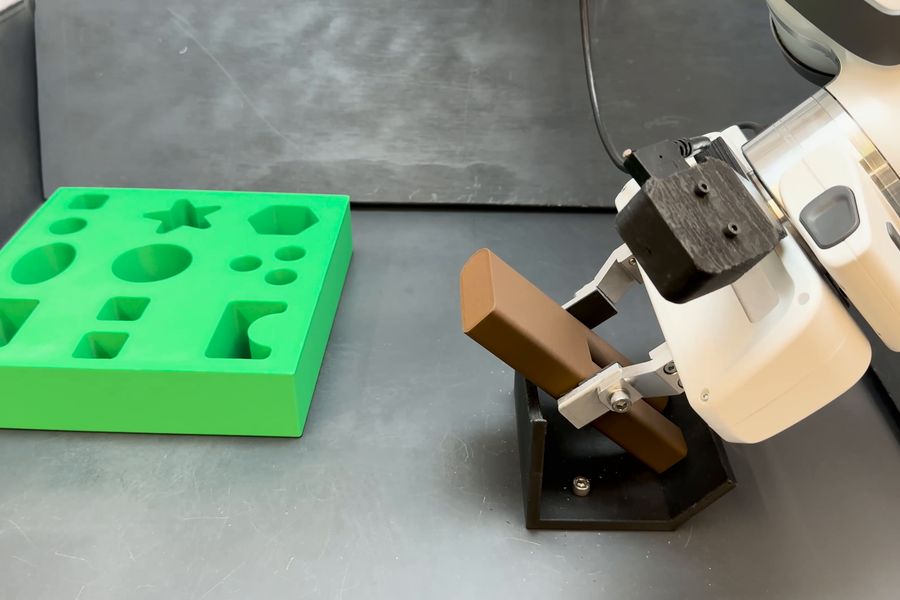
Frame from the FMB: Functional Manipulation Benchmark dataset, UC Berkeley RAIL, CC BY 4.0.
CC BY 4.0
The publisher's licence permits commercial use and redistribution, with attribution.
wget https://rail.eecs.berkeley.edu/datasets/fmb/single_object_manipulation.zipFour zip archives: Single-Object 545 GB, Assembly 1 86 GB, Assembly 2 77 GB, Assembly 3 70 GB. Single-request downloads from a university server; no token. Also included in Open X-Embodiment as fmb (RLDS) but that mirror was not verified here.
Specification, as published
- Hours (derived)
- 31 h
- Episodes (stated)
- 22,550 episodes
- Scale
- We collected a total of 22,550 trajectories across two different tasks on a Franka Panda arm.
- Task
- Assembly, Pick & place
- Environment
- Indoor – lab
- Modality
- RGB, Depth, Proprioception, Actions, Force/torque
- Capture
- CCTV Scene
- In frame
- Robot hands
- Captured in
- North America
- Embodiment
- Franka Panda
- Resolution
- 256x256
- Formats
- NPZ/NumPy, Other
- Size
- 545 GB (Single-Object) + 86 GB + 77 GB + 70 GB (Assembly 1 to 3)
- Hosted on
- rail.eecs.berkeley.edu
Figures are the publisher's own. Kinetic Blocks has not measured this dataset. Estimated from the paper: 22,550 trajectories of about 5 seconds each. The publisher states no total.
About this dataset
FMB is a real-robot benchmark from UC Berkeley focused on the sub-skills of assembly: grasping, repositioning and inserting objects into boards. A Franka Panda arm was teleoperated with a SpaceMouse over 54 single objects and three sets of interlocking multi-object assemblies. Each trajectory carries two global and two wrist RGB-D views plus end-effector pose, velocity, force/torque, joint state and gripper state, stored as NumPy files in four large zip archives.
Publisher's own task names: grasping, repositioning (place, regrasp, rotate), insertion, single-object multi-stage assembly, multi-object assembly.
What Kinetic Blocks did, and did not do
Indexed and linked from the publisher. Not hosted, verified or graded by Kinetic Blocks. The publisher's terms govern. The licence shown is the one stated on the publisher's page, linked above. Nothing on this page is a claim by Kinetic Blocks.
Want the verified ones too?
Request access to the marketplace, where every paid listing is verified against its files and graded before it goes on sale.